Article Sections
Generalized predictive control for DEAP flexible bionic actuator with fuzzy model
Loading author information...
Graphical Abstract & Abstract
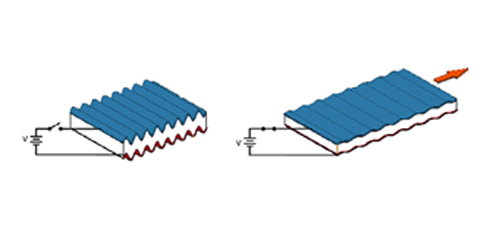
Dielectric electro-active polymer (DEAP) is novel type of flexible smart materials, which have advantages of lightweight, high energy density and fast response, making them especially suitable for the actuator material of bionic robots. However, DEAP materials generally have hysteresis effect, creep, uncertainty and nonlinear characteristic, and result in challenges for control strategies. To address this issue, an improved generalized predictive control (GPC) strategy based on T-S fuzzy model is presented in this paper. T-S model is adopted to model for DEAP actuator and GPC controller is developed based on the model. A position tracking experiment was conducted with the DEAP experiment platform. The experimental results show that this control strategy has high tracking accuracy and fast response speed, and the proposed model and control method for EAP flexible actuator were verified.
How to Cite
(2018). Generalized predictive control for DEAP flexible bionic actuator with fuzzy model. Advanced Materials Letters, 9(2), 132-137. https://doi.org/10.5185/amlett.2018.1928